

G1
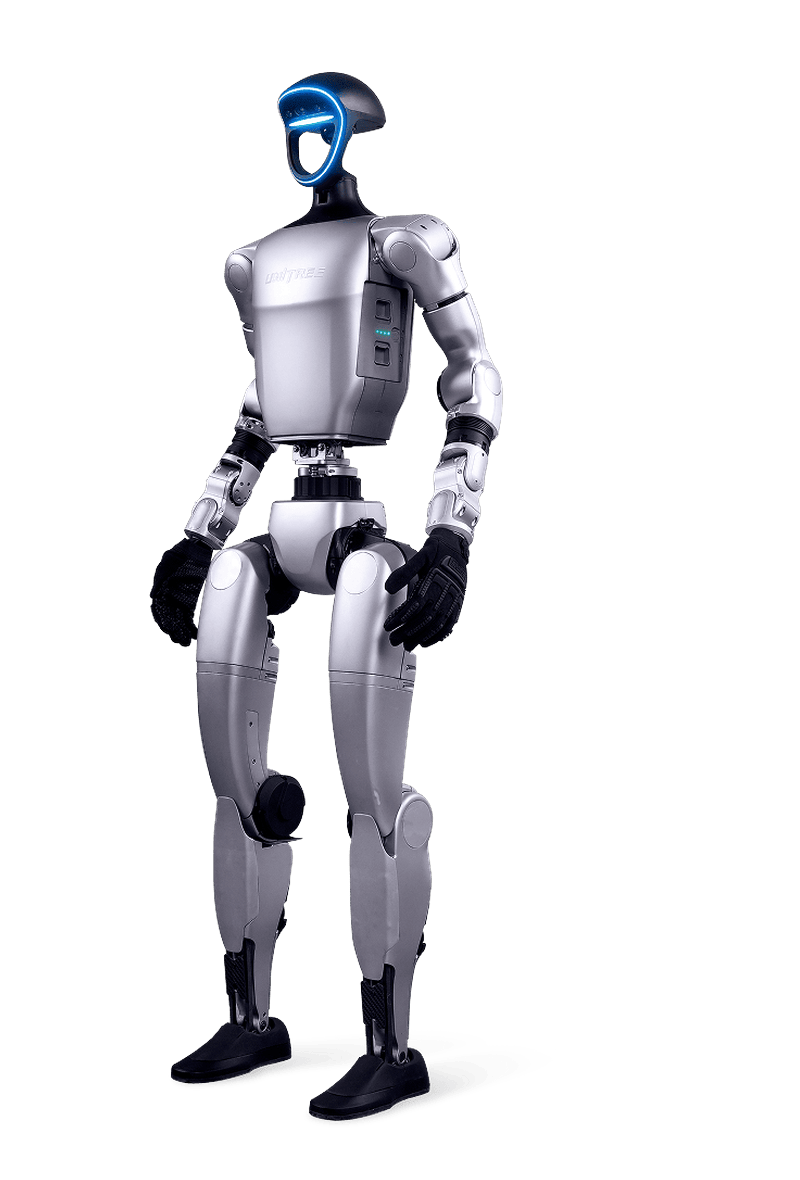
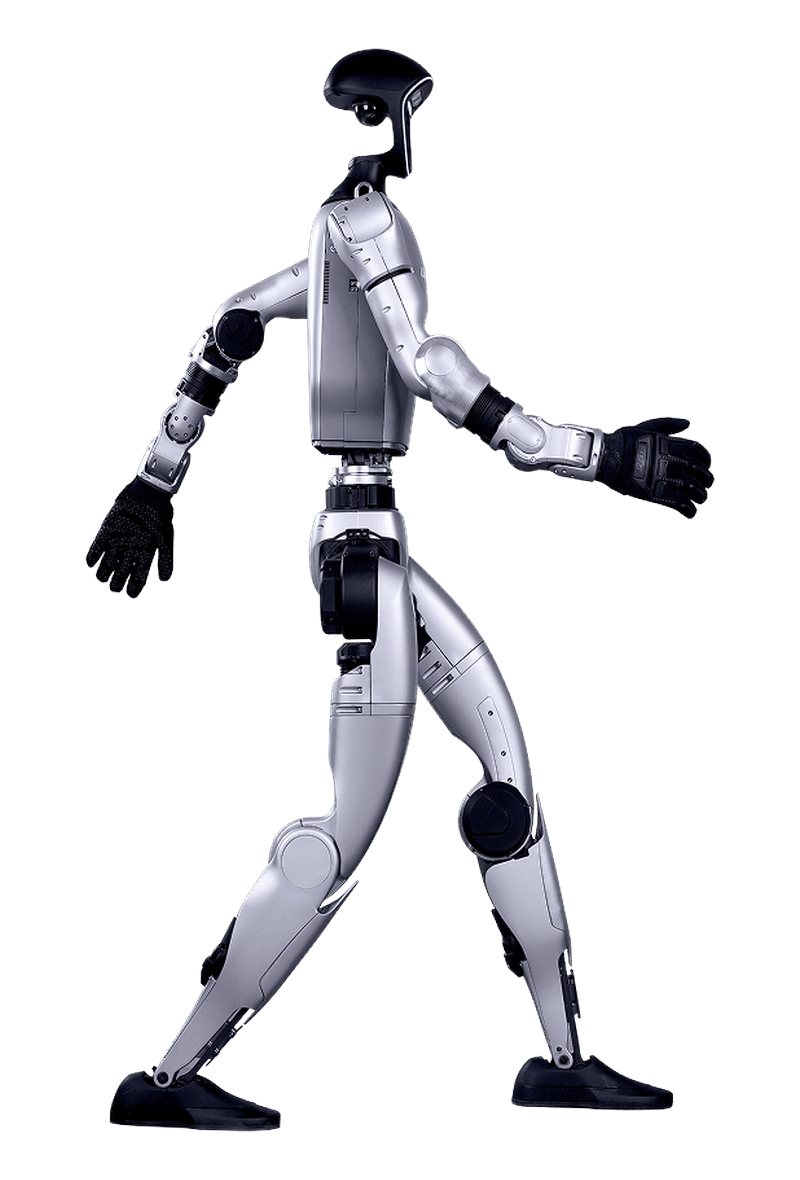
About the size of a small adult and roughly as heavy as a medium suitcase. Its size makes it ideal for use at exhibitions and events.
Staffing / Rental
¥100,000/day+
Buy
Quoted on request
CASE STUDIES
STRENGTHS
Strengths of the Unitree G1
The G1 is a humanoid robot designed to move in the same space as people and to put AI to work onboard. Here we lay out the reasons it is chosen by research institutions, corporate R&D divisions, and educational institutions.
A wide range of motion close to the human body
What defines the G1’s body is the breadth of its joint range of motion. Equipped with 23-43 joint motors depending on configuration, it offers ±155° waist rotation, ±154° forward/backward at the hip, and 0-165° at the knee, a range close to the human body. It naturally performs a sequence of motions such as walking, crouching, twisting, and reaching.
Industrial-grade high-precision bearings
Cross-roller bearings in the joint drive units combine high precision with durability under heavy loads
High-efficiency joint motors
A fast-responding structure that dissipates heat easily, enabling crisp, agile movement
3D LiDAR
Reads the surrounding shapes in three dimensions, used for obstacle recognition and spatial awareness. Specific model numbers are provided in the configuration documents
Depth camera
Measures the distance to objects ahead. Specific model numbers are provided in the configuration documents
Internal wiring
Routing the wiring inside the joints reduces the risk of breakage while securing a wide range of motion
Dual angle sensors
Measure joint position with high accuracy
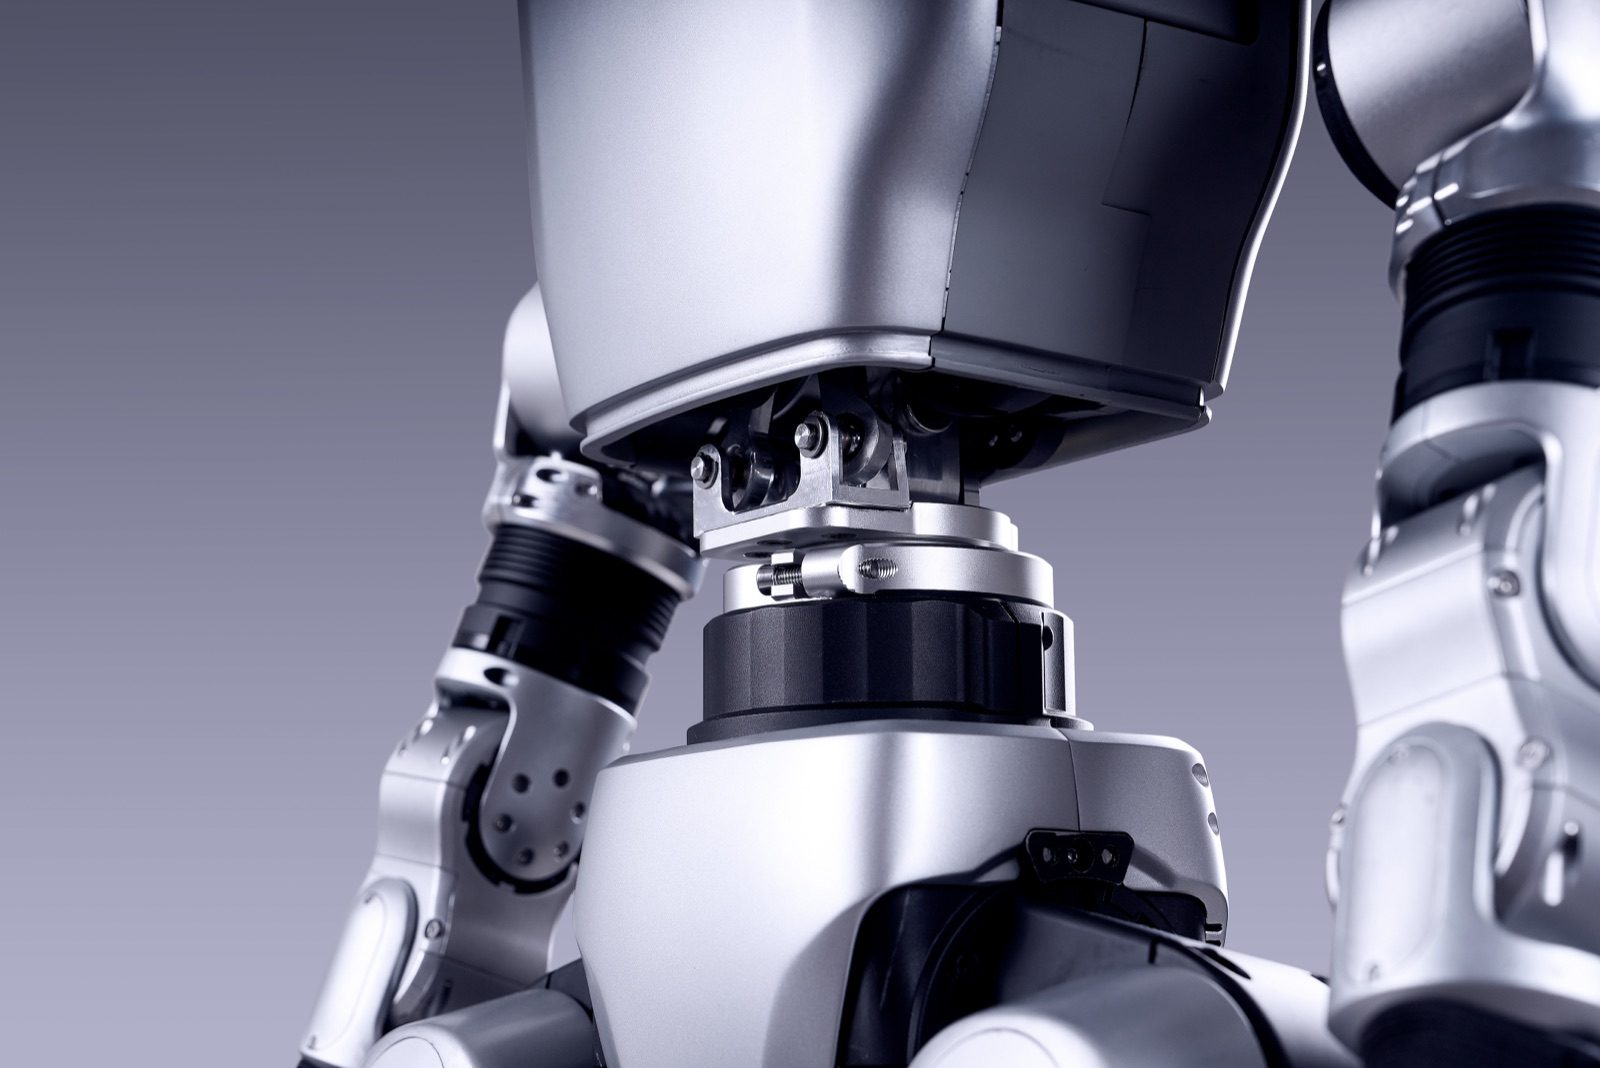
Waist
The waist rotates ±155° left and right, with higher configurations adding ±45° forward/backward tilt and ±30° side tilt. It handles the upper-body movements of twisting and leaning the torso.
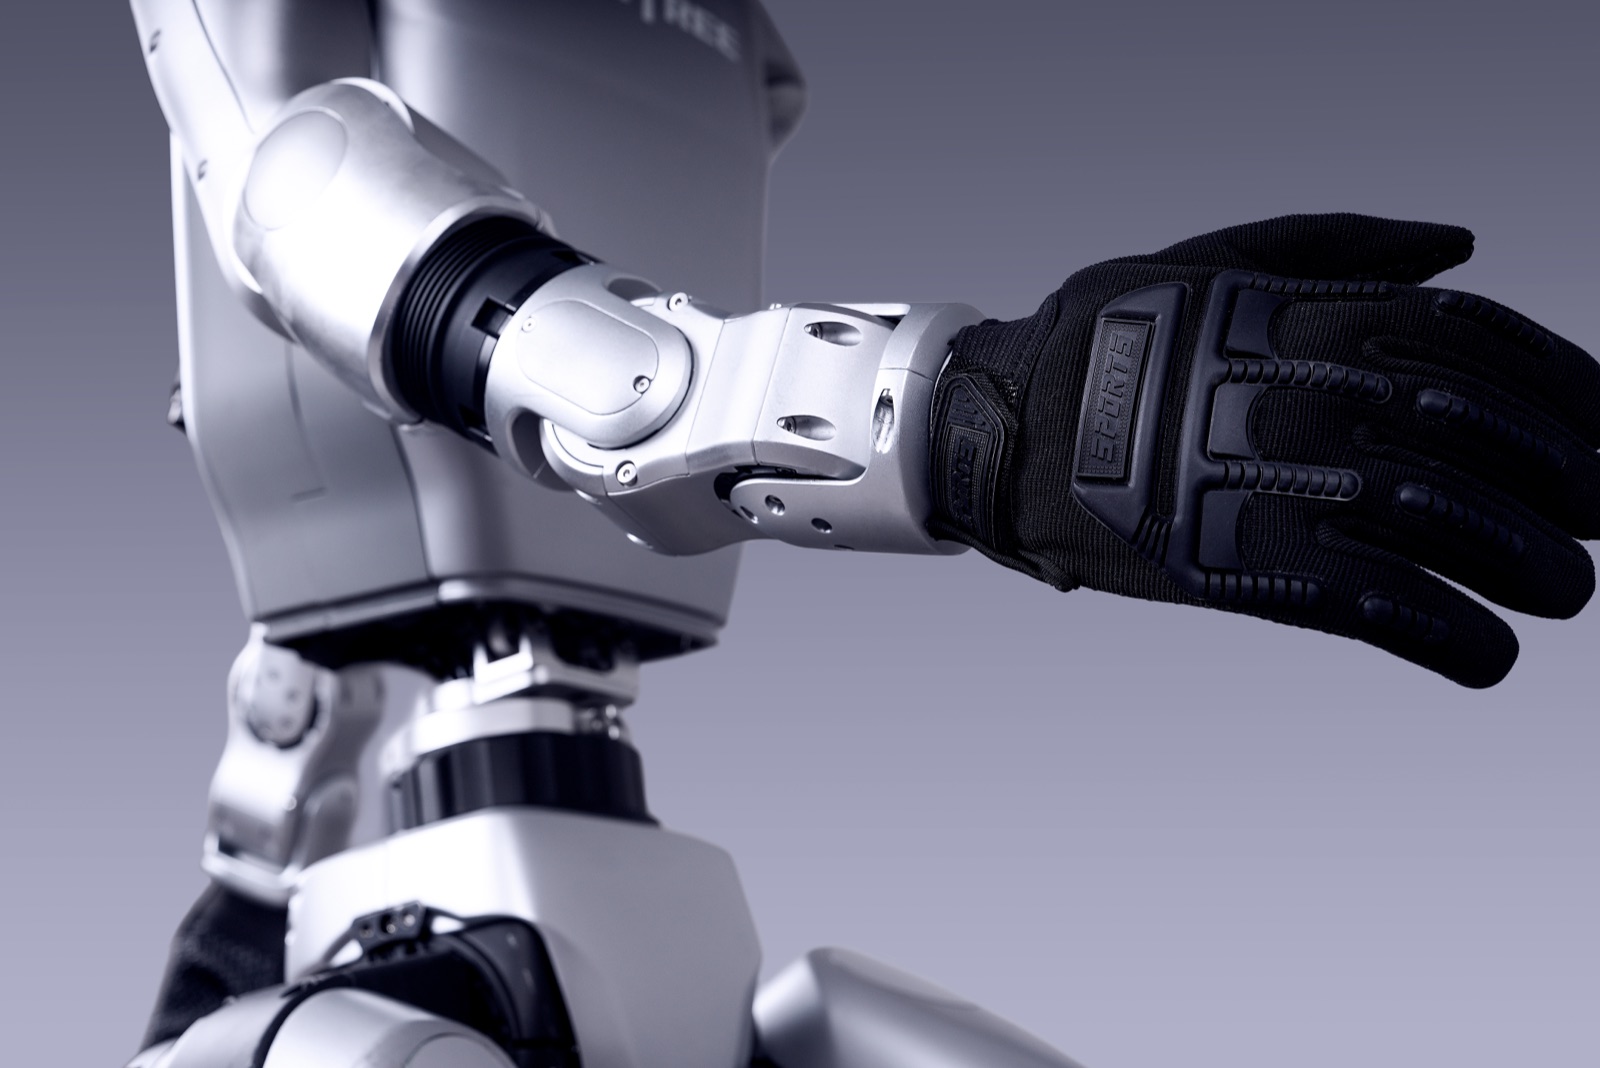
Arm
Each arm moves with five joints, with two more available at the wrist in higher configurations. Payload is approx. 2kg on Basic and approx. 3kg on higher configurations. The arm is about 0.45m long, so its movements feel natural alongside a person.
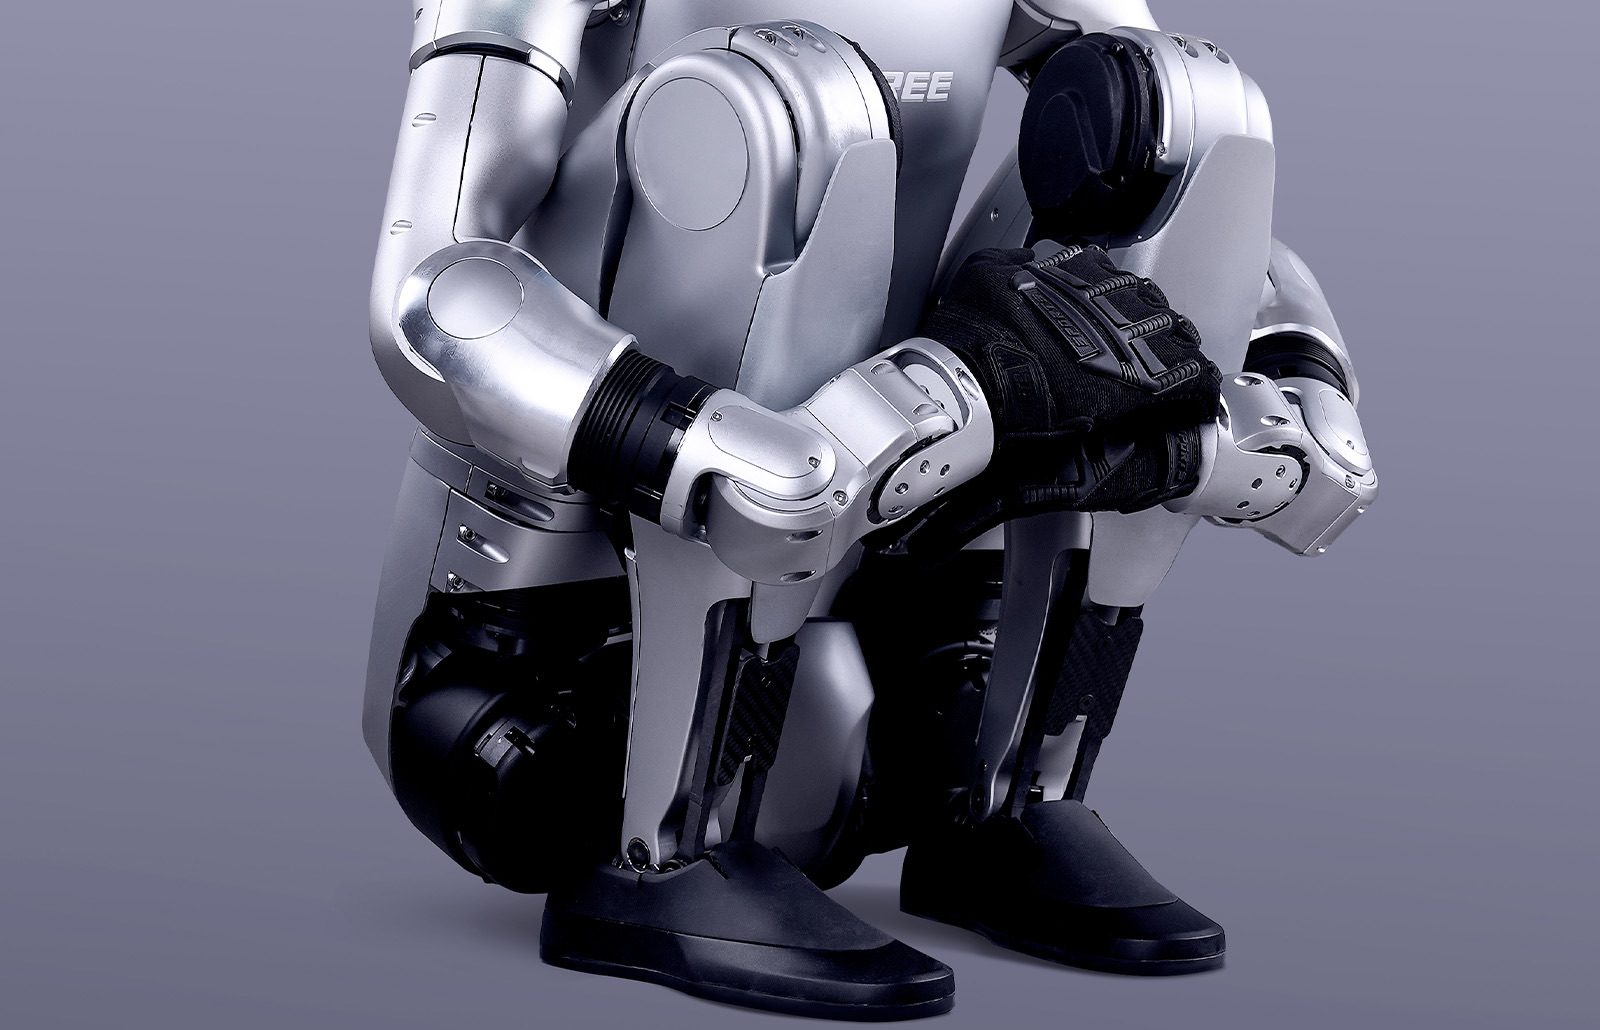
Leg
Each leg moves with six joints (3 hip + 1 knee + 2 ankle). The knee moves 0-165°, and the hip offers ±154° forward/backward, -30 to +170° lateral, and ±158° rotation, providing a range close to the human body. The combined calf and thigh length is 0.6m.
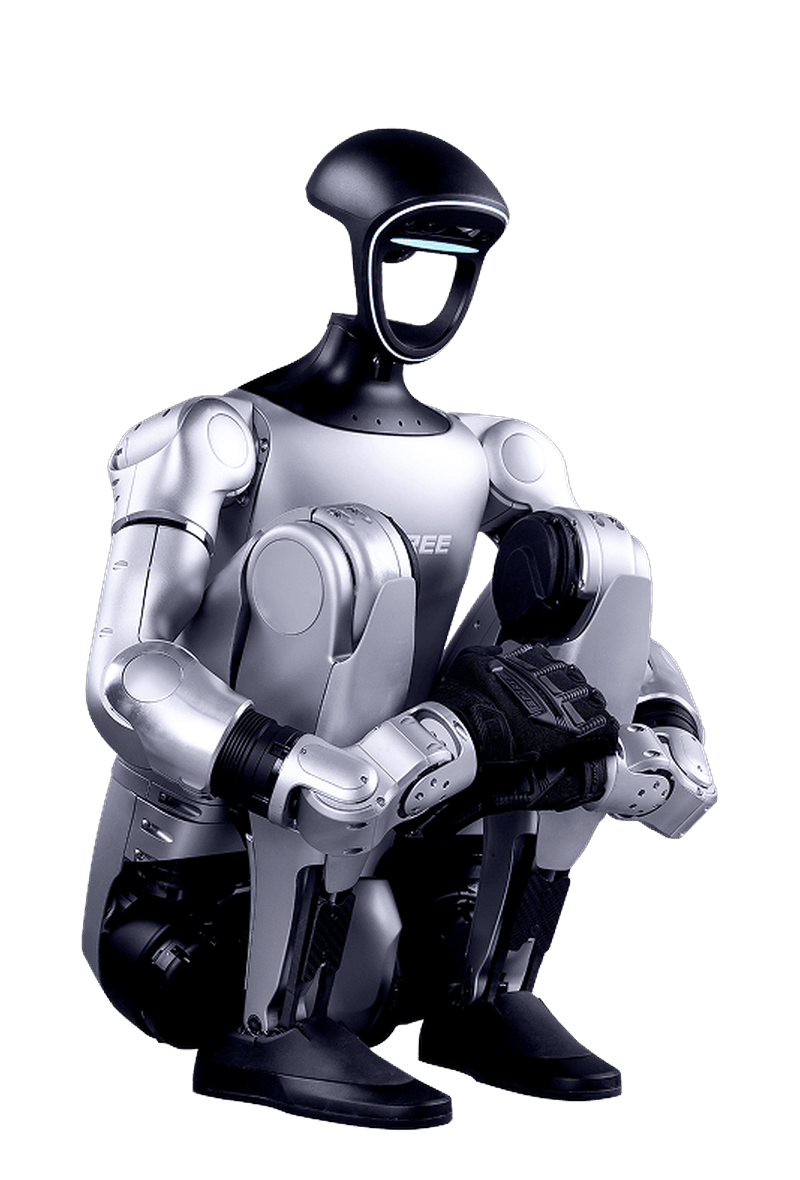
A compact, foldable body
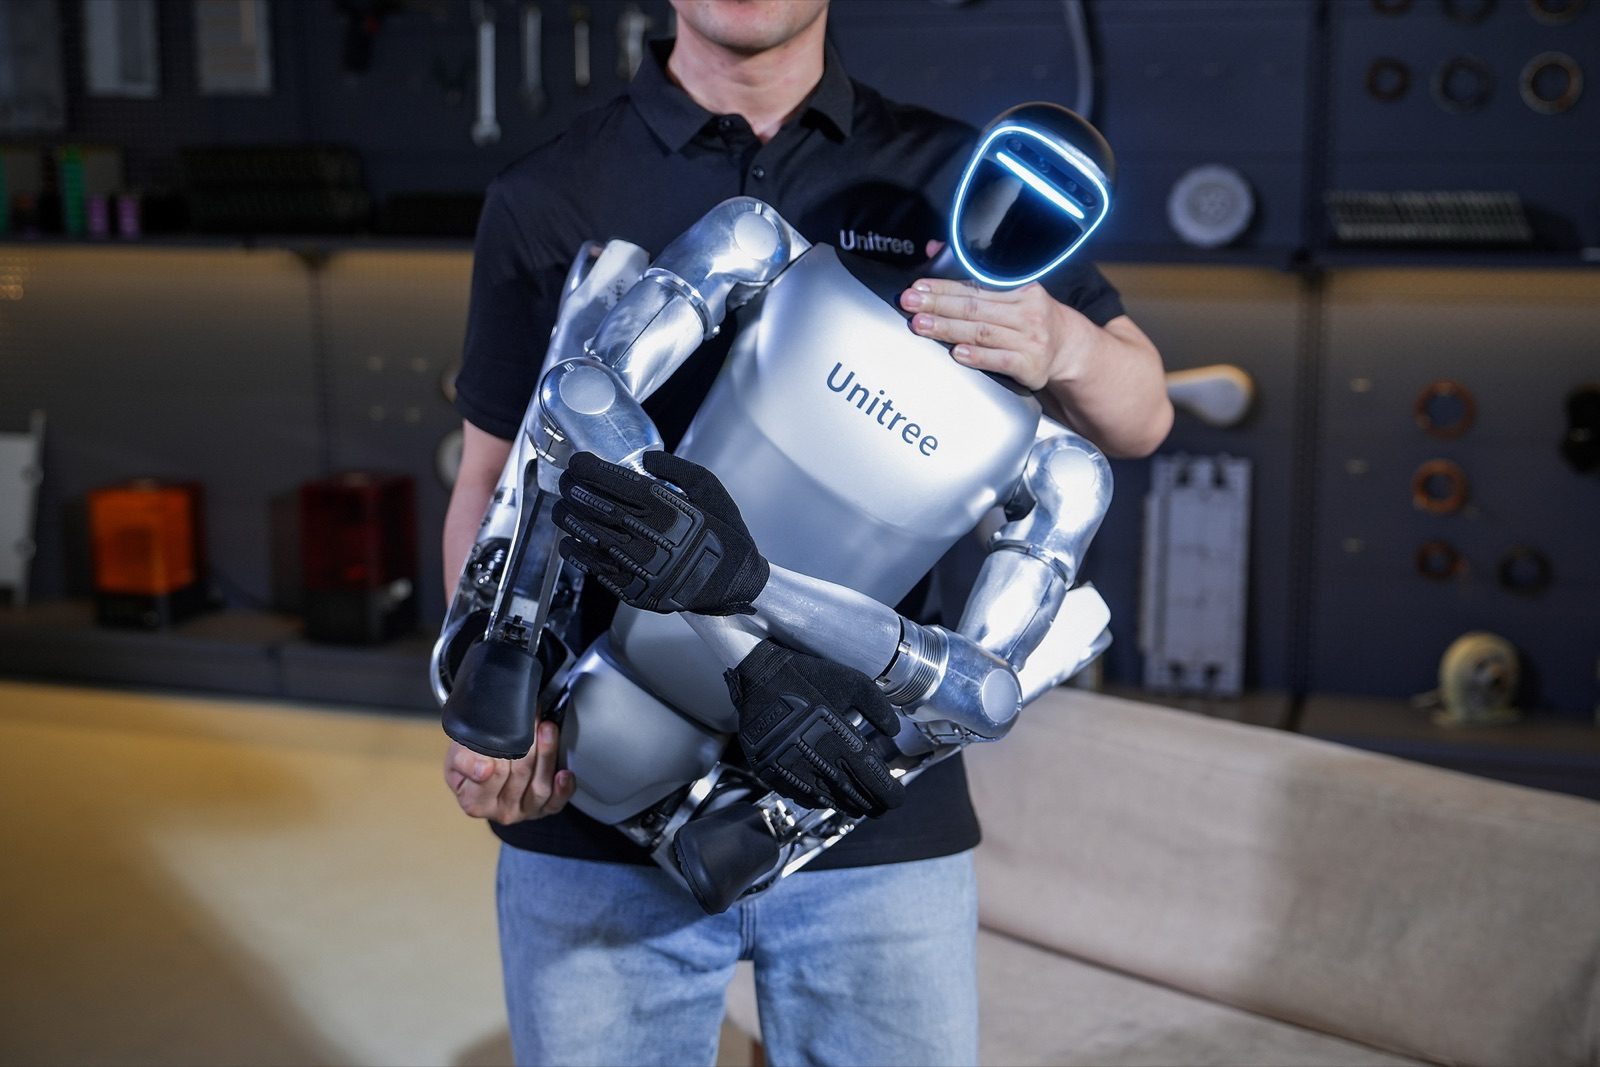
The G1 folds down to as small as 690×450×300mm when folded. It is an easy-to-handle size for uses such as moving in and out of exhibitions, carrying it between labs, and on-site demos away from the office.
Because it weighs approx. 35kg with the battery, transport is realistically handled by two people or with a dedicated cart or carrier.
A battery you can swap without tools
What supports the G1’s continuous operation is a battery you can quickly attach and detach without tools. Because you can keep running by swapping in a spare battery, it handles long-duration use such as exhibitions, full-day demos, and filming sets.
Power supply
9,000mAh
Battery runtime
Approx. 2 hours (varies with the task)
Battery swap
Quick tool-free attach and detach mechanism
For sites with continuous operation such as exhibitions and full-day demos, we recommend preparing one or two spare batteries. Please consult us about this when you contact us.
Whole-body motion that keeps balance while moving
The G1 is not a humanoid robot that merely stands and walks. Thanks to control that keeps it balancing on its own while moving, the following motions are possible.
Walking & running
Approx. 2 m/s (varies with configuration and surface conditions)
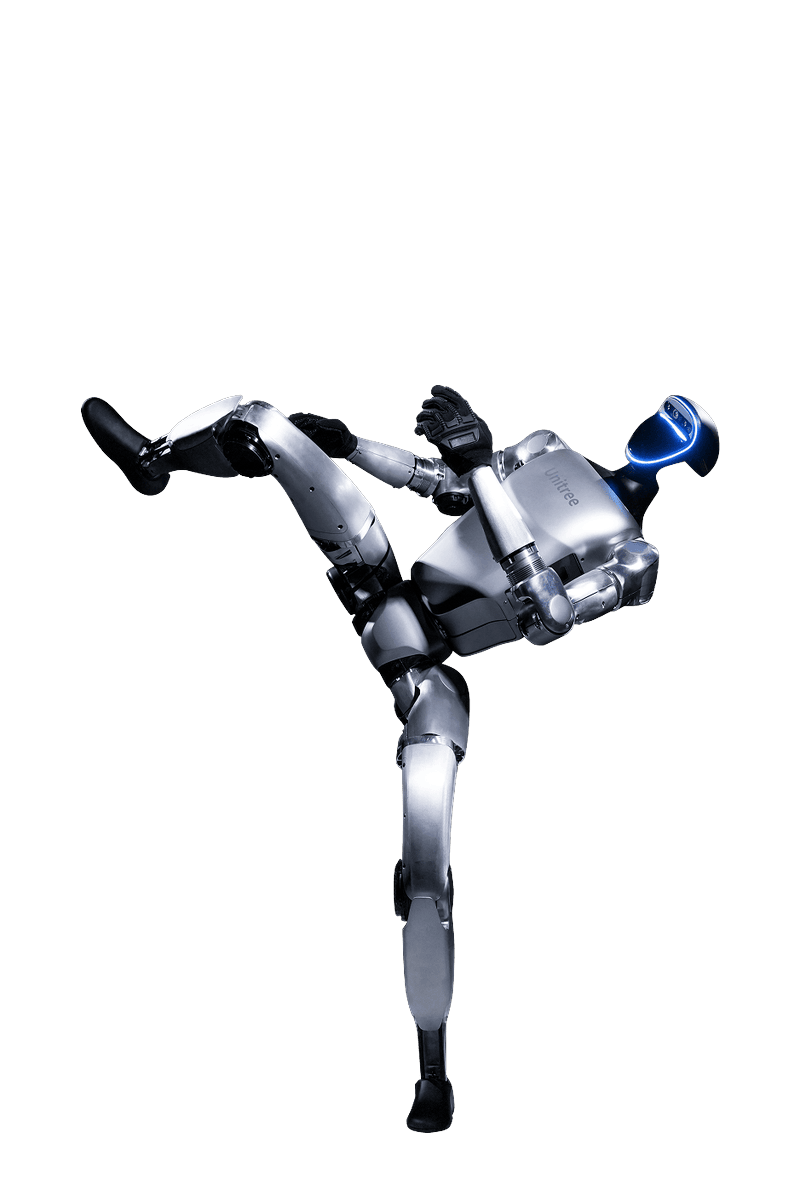
Jumps & backflips
Performs standing jumps, continuous jumps while running, and backflips on the spot
Clearing obstacles
Climbing stairs and steps has been confirmed in demos and research examples (the exact height varies with configuration and operating conditions)
Kung-fu routines
At the 2026 Spring Festival Gala (CCTV), G1 and H2 units autonomously performed a group kung-fu routine
Recovers when pushed
Even when pushed by a person or with a leg pulled, it quickly regains its posture
Autonomous walking in extreme cold
In February 2026, in the -47.4℃ environment of the Altay region of Xinjiang, it carried out a public demo walking over 130,000 steps and tracing emblems related to the Winter Olympics
Multi-finger hands with adjustable grip force
One of the G1’s core capabilities is multi-finger hands that can finely adjust grip force across multiple fingers. Because force can be adjusted at each finger joint, it can firmly grasp not only hard objects but also soft objects and objects of different shapes. It is a configuration suited to research and validation where you want to verify tasks performed in the same environment as people, such as cooking, serving, and assembly, on an actual unit. With the Edu Ultimate configuration, you can choose from a variety of hand options to match your use case.
Dex3-1 (without tactile sensing)
Three fingers with adjustable grip force, with seven joints in total
Dex3-1 (with 33 tactile sensors)
The above plus 33 added tactile sensors
Inspire RH56DFQ-2R / 2L
Five fingers
Inspire RH56DFTP-2R / 2L (17 tactile sensors)
Five fingers plus 17 tactile sensors
BrainCo Revo 2 Basic
BrainCo five-finger hand
BrainCo Revo 2 Touch
BrainCo five-finger hand plus tactile sensors
With the Edu Professional configuration, the hand options differ by configuration. It is equipped with one of the tactile-free Dex3-1, the Inspire five-finger hand, or the BrainCo Revo 2 Basic / Touch, so you can choose to match your research theme. Among them, the Dex3-1 is the representative hand of the higher G1 configurations, featuring three fingers, grip-force adjustment, and 33 tactile sensors (on tactile configurations). If you are planning research on grasping and manipulating objects from the start, it is efficient to include the Dex3-1 at the time of the initial order. This shortens the time required for procurement and integration compared with adding it later.
SPECS
Detailed Specifications
The 13 configurations broadly split into two lines: the Basic series and the higher (Edu) series. Because the price and feature differences are clear-cut, it is efficient to choose based on your use case. A simple guideline: choose Basic if the goal is to put it on show, and a higher configuration if the goal is hands-on research and development.
| Item | G1 Basic | G1 Higher (Edu series) |
|---|---|---|
| Dimensions (folded, H×W×D) | 690×450×300mm | Same as left |
| Weight (incl. battery) | Approx. 35kg | Approx. 35kg |
| Total degrees of freedom | 23 | 23-43 |
| Degrees of freedom per leg | 6 | 6 |
| Waist degrees of freedom | 1 | 1-3 (optional +2) |
| Degrees of freedom per arm | 5 | 5 (optional wrist +2) |
| Degrees of freedom per hand | None | Three-finger / five-finger / tactile hand selectable by configuration |
| Max. knee joint torque | 90 N·m | 120 N·m |
| Max. arm payload | Approx. 2kg | Approx. 3kg |
| Joint motors | Low-inertia, high-speed inner-rotor PMSM | Same as left |
| Joint bearings | Industrial-grade cross-roller bearings | Same as left |
| Joint encoders | Dual encoders | Same as left |
| Electrical wiring | Wiring routed inside the joints | Same as left |
| Cooling method | Localized air cooling | Same as left |
| Sensors | Depth camera + 3D LiDAR | Same as left (specific model numbers in the configuration documents) |
| Computing | 8-core high-performance CPU | 8-core CPU + NVIDIA Jetson Orin (optional) |
| Battery | 13-series lithium 9,000mAh / quick-release | Same as left |
| Charger | 54V 5A | Same as left |
| Battery runtime | Approx. 2 hours | Approx. 2 hours |
| Travel speed | Approx. 2 m/s (varies with configuration and surface) | Same as left |
| Clearing steps | Public demos and research examples available (confirm real-world use by configuration and conditions) | Same as left |
| Communication | WiFi 6 / Bluetooth 5.2 | Same as left |
| Audio | 4-mic array + 5W speaker | Same as left |
| Intelligent OTA | Supported | Supported |
| Secondary development | Not supported | Supported |
| Warranty | 8 months | 18 months |
| Reference price (excl. tax & shipping) | Contact us | Contact us |
Specifications vary with configuration and operating scenario. Please contact us for final specifications and domestic pricing.
CASE STUDIES
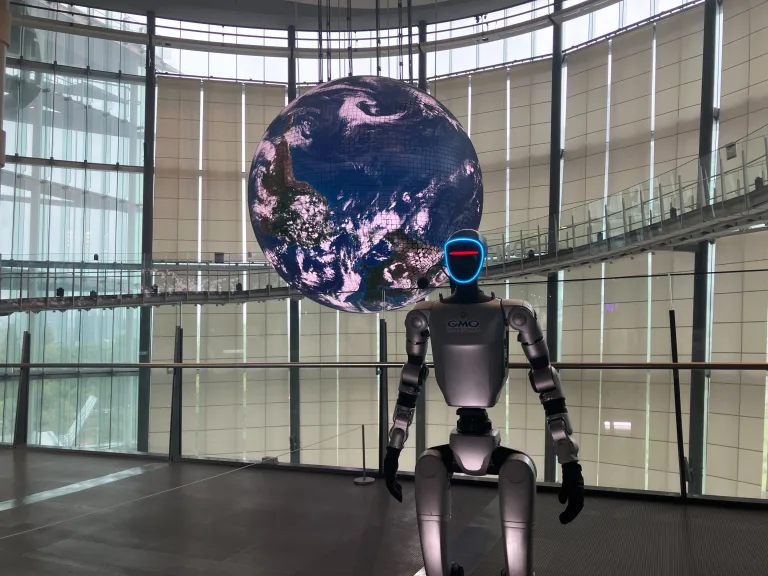
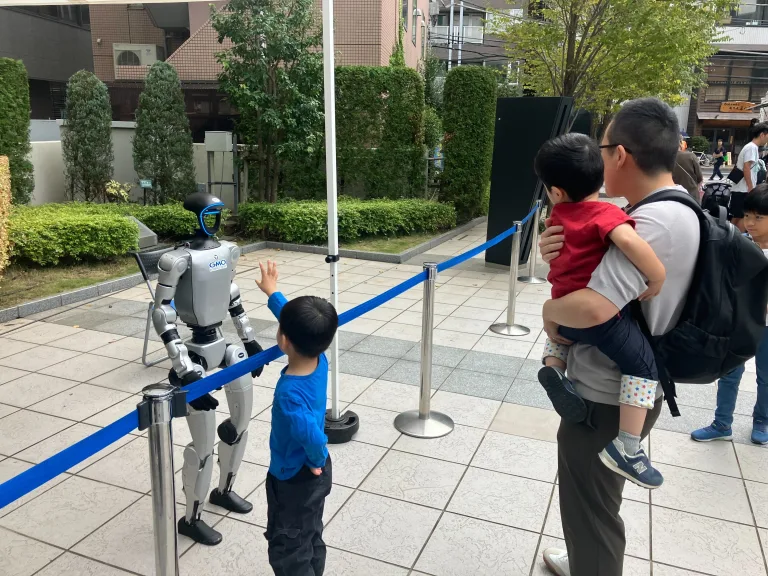
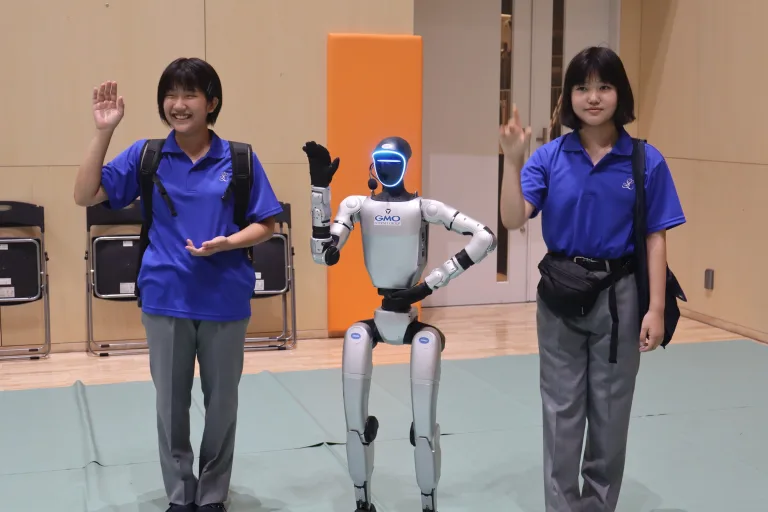
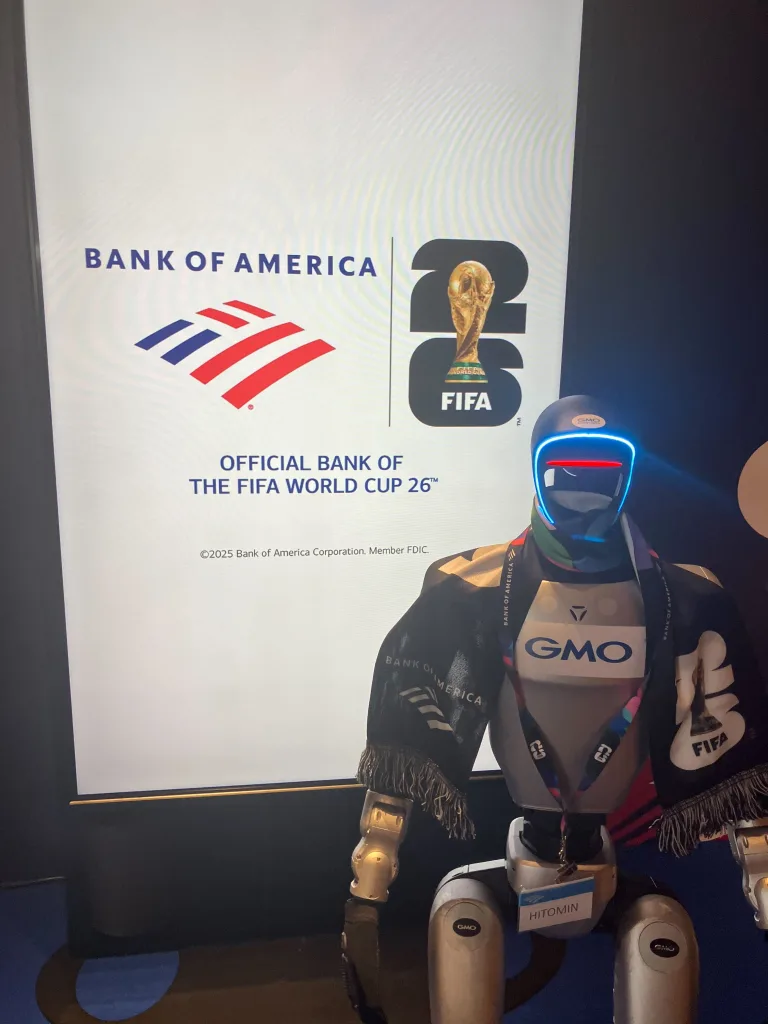
Case studies
Q & A
FAQ
How much does it cost?
You can choose from 13 configurations. Because the domestic sales price varies with configuration, exchange rates, and incidental costs, we provide an individual quote through the contact form.
What is the lead time?
For configurations in stock, the guideline is about two weeks; for configurations that require made-to-order production, about one month. We will confirm the exact lead time based on stock at the time of order.
Can I try it on rental before buying?
Yes. You can arrange a short-term rental through the GMO AIR humanoid staffing service. Plans that include accompanying operating staff are also available, so please consult us according to your needs for prototyping and validation, exhibitions, or in-house demos.
How many degrees of freedom does it have?
The Basic configuration has 23, and higher (Edu-series) configurations can be chosen with up to 43. This increases or decreases with the waist joint option (+2) and the addition of Dex3-1 hands (7 degrees of freedom × 2).
Can I write my own programs to add features?
With a higher (Edu-series) configuration, you can write your own programs to develop and add features, and a development manual is included. If you plan to do development, choose a higher configuration.
Does it support ROS?
Development tools and a complete set of programs for "ROS / ROS 2", the control software widely used in robotics development, are publicly available. Supported versions and sample programs for the G1 are also provided, so you can make use of them according to what you are developing.
Can a Jetson Orin be installed?
Yes. As an add-on part for higher (Edu-series) configurations, you can install an NVIDIA Jetson Orin for AI processing. Choose this if you want to run your own AI or trained motion programs on the actual unit.
What is UnifoLM-VLA-0?
It is an AI published by Unitree that sees, receives spoken instructions, and acts, together with its training data and a full set of programs. It enables validation of household tasks based on spoken instructions and validation of operation on actual G1 units. Please check the publication source and license for the usage terms, target tasks, and the scope of application to the actual unit.
Can I run motion simulations on a computer?
unitree_mujoco and unitree_rl_gym are publicly available, letting you test the G1’s movements in a virtual space on a computer. They can be used to validate motion before running the actual unit. Please confirm in advance the available simulation environments, model settings, and the scope of the procedure for transferring movements in the virtual space to the actual unit.
How long does the battery last?
With a quick-release-compatible 9,000mAh battery, the runtime is approximately two hours. We will confirm the operating-time design including spare batteries based on the task, temperature, safety stops, and charging setup.
Has it passed safety certifications such as PSE?
For the domestic market, we deliver configurations compliant with electrical safety standards such as PSE. Please confirm the details when you contact us.
How does maintenance and repair work?
Within the warranty period (Basic 8 months / higher 18 months) we provide service free of charge, and outside that period we accept paid repairs.
Is there any difference from the overseas model?
The basic specifications are confirmed within the same framework as the global documents, but for the domestic market we deliver configurations compliant with electrical safety such as PSE. The final accessories, charger, warranty, and certification compliance are confirmed at the time of quotation.
How does it differ from other humanoid makers?
The G1 stands out for being easy to evaluate by combining a published price range, domestic purchase consultation, development configurations, and documentation for publicly available development tools and simulation environments. Other companies’ models differ in sales regions, partnership terms, lead times, and the scope of what is made available to developers. That makes the G1 one of the easier candidates to compare for a purchase decision as a first unit for research, education, and exhibition.
What kinds of uses is it suited for?
It is suited for hands-on uses with a humanoid robot such as R&D, education, exhibitions, prototyping and validation, and filming. The arm payload is 2-3kg per side, and battery runtime is approximately two hours. Suitability for indoor demos, training, and experiments is judged based on the task and safety conditions.
PRODUCTS
Products
We offer the latest models suited to a wide range of use cases —
from R&D and proof-of-concept trials to entertainment.
-
 Unitree A2 / A2-W
長く走れて重い荷物を運べる、四足歩行ロボット
-
 Unitree As2 / As2-W
扱いやすい、小型の四足歩行ロボット
-
 Unitree B2 / B2-W
重い荷物を運べる、大型の四足歩行ロボット
-
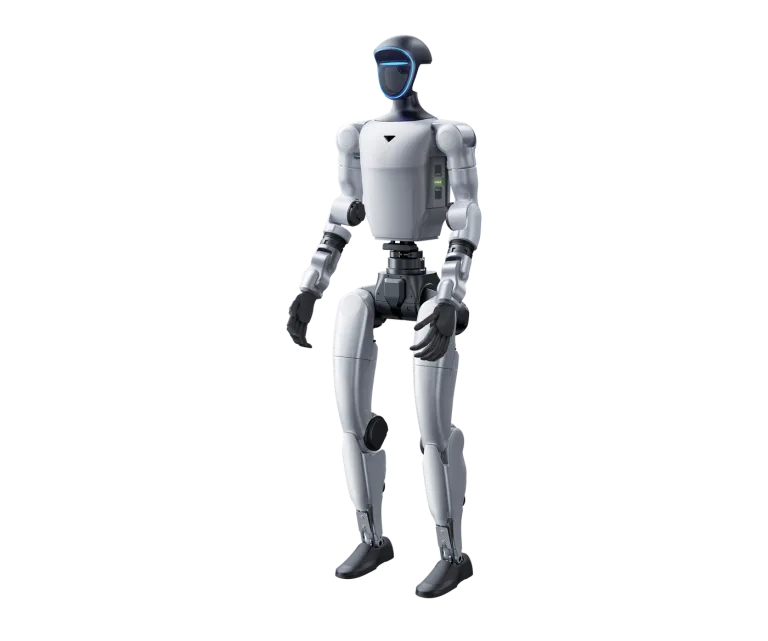 Unitree G1
様々な用途に使える、汎用の人型ロボット
-
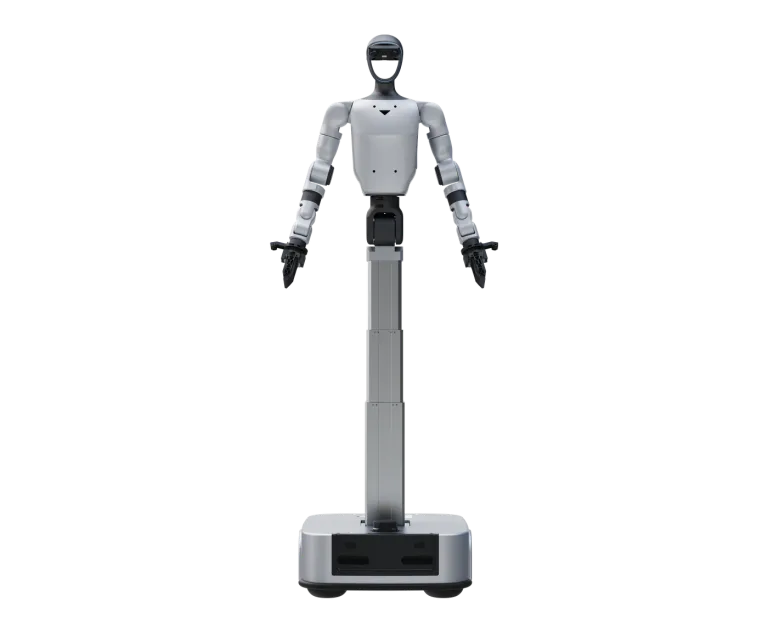 Unitree G1-D
G1の脚の代わりに台座を使って、平らな場所で安定して動かせるようにした人型ロボット
-
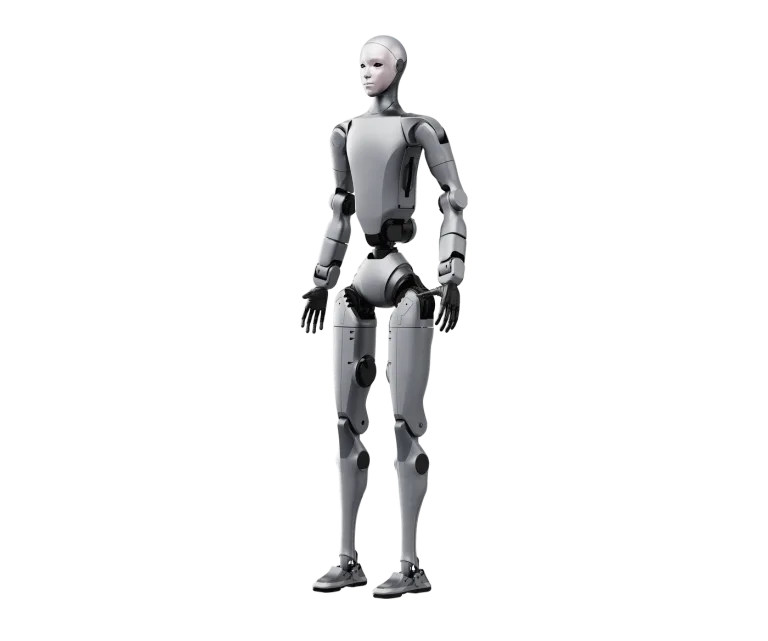 Unitree H2
人と同じ大きさで、重い物を扱える大型の人型ロボット
-
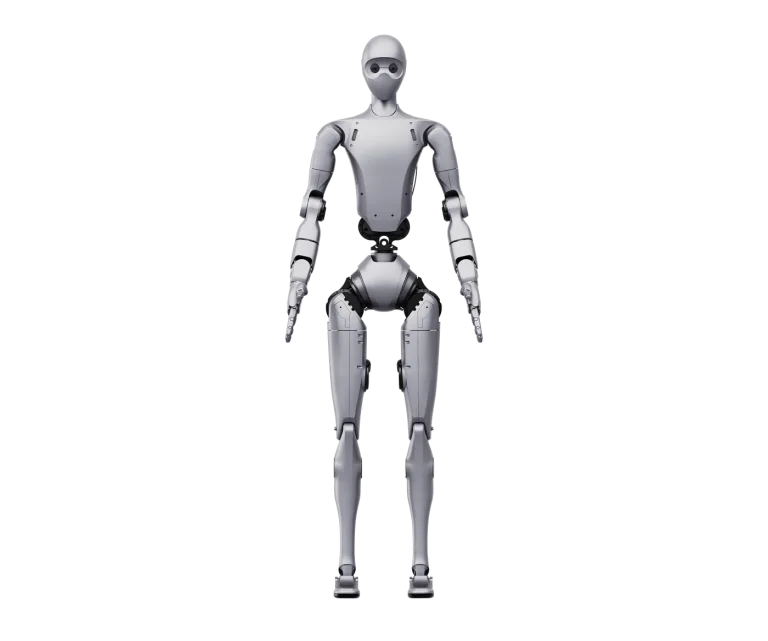 Unitree H2 Plus
H2にNVIDIA Jetson Thorを積み、顔と頭部のカメラを専用にした大型の人型ロボット
-
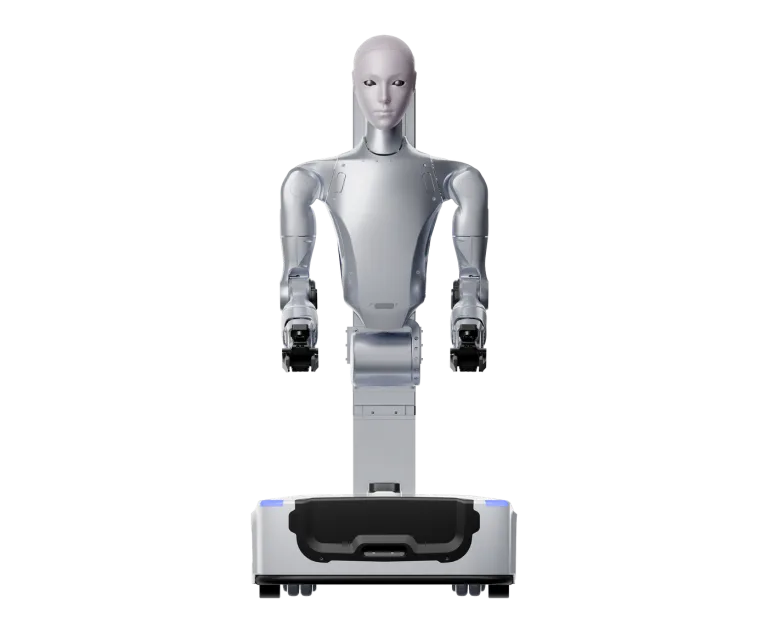 Unitree H2-A / H2-D
H2の脚を外して双腕にし、上半身を据えるか台座に載せて使うロボット
-
 Unitree R1
軽くて扱いやすい小型の人型ロボット
-
 Unitree R1-A / R1-A-D
R1の脚の代わりに台座を使って、平らな場所で安定して動かせるようにした双腕のロボット
-
 BrainCo Revo 2 5指ハンド(触覚)
4種類の触覚を持つ5指ハンド
-
 BrainCo Revo 3 U21T 5指ハンド(触覚)
21自由度で触覚を持つ5指ハンド
-
BrainCo Revo 3 U21VT 5指ハンド(視触覚)
指先に視触覚を持つ5指ハンド
-
 Dex1-1 グリッパー上位版
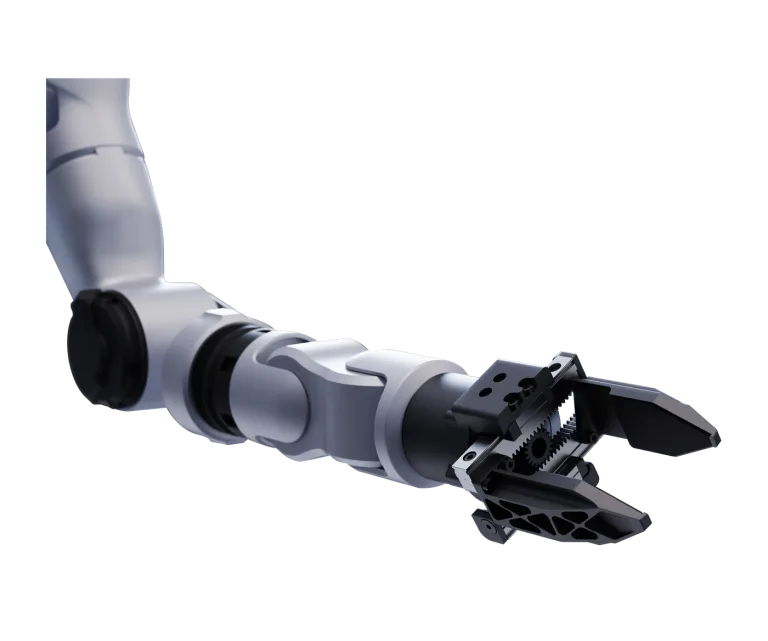
手首カメラ付きの平行2爪グリッパー
-
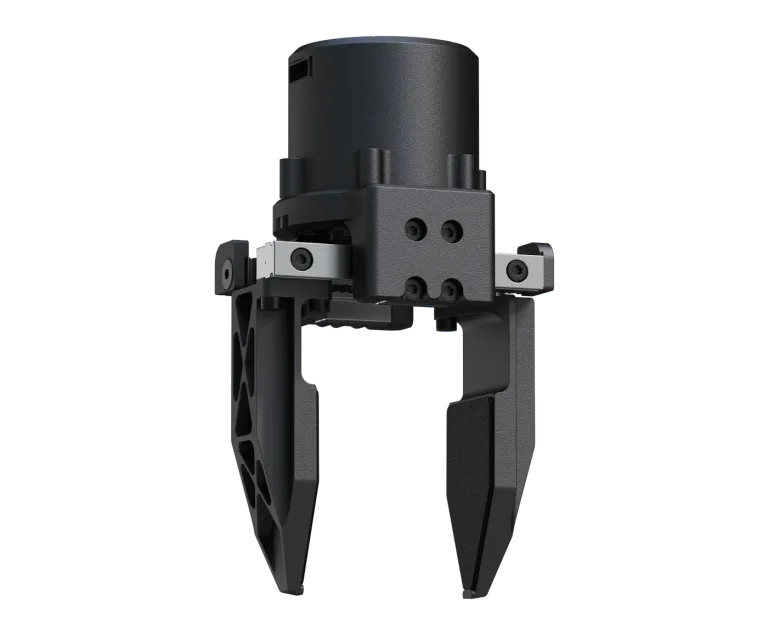 Dex1-1 グリッパー標準版
G1・R1系に付く平行2爪のグリッパー
-
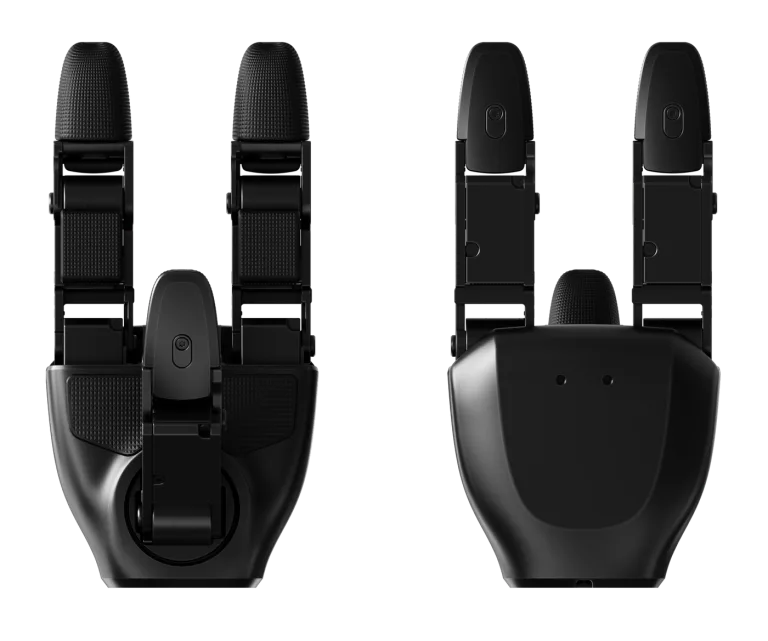 Dex3-1 力制御3指ハンド(触覚)
触覚を持つ3指のハンド
-
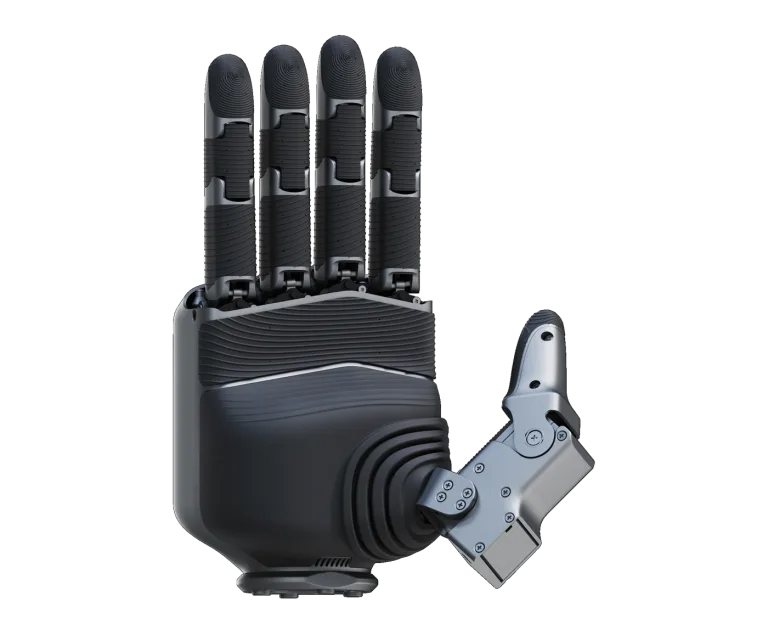 Dex5-1 5指ハンド
H2-A・H2-D用の16自由度5指ハンド
-
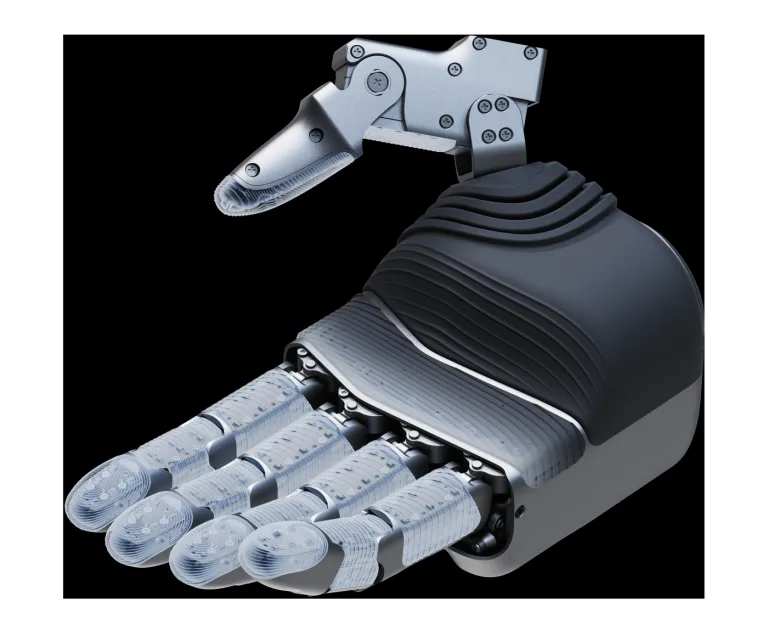 Dex5-1P 5指ハンド(触覚)
触覚を持つ16自由度の5指ハンド
-
 G1-E NX モジュール
G1-E用の100TOPSモジュール
-
 Linker Hand O6 5指ハンド(触覚)
リンク駆動で触覚を持つ5指ハンド
-
 SharpaWave Hand 2 5指ハンド
指先に視触覚を持つ22自由度のハンド
-
 WUJI Hand 2 5指ハンド
人の手に近い20自由度の5指ハンド